Kenta Tanaka
Assistant Professor | Ph.D. in Engineering
Artificial Intelligence and Informatics
Systems and Mathematical Analysis Engineering Research Group
In my lectures, I aim for students to move beyond a superficial understanding based only on memorizing formulas and procedures and to discover for themselves why things work as they do.
In my research, I belong to the Systems and Mathematical Analysis Engineering Research Group, which combines insights gained from data analysis and mathematical analysis of system behavior to develop systems that benefit society.
Improving Human-Machine Operability through Information Alteration
What students can learn
In addition to the fundamentals of control theory and simulation techniques using Python, students can learn interface development using XR technologies such as Unity. Through operating experiments involving human participants, they also gain experience in the full process of planning, conducting, and analyzing experiments.
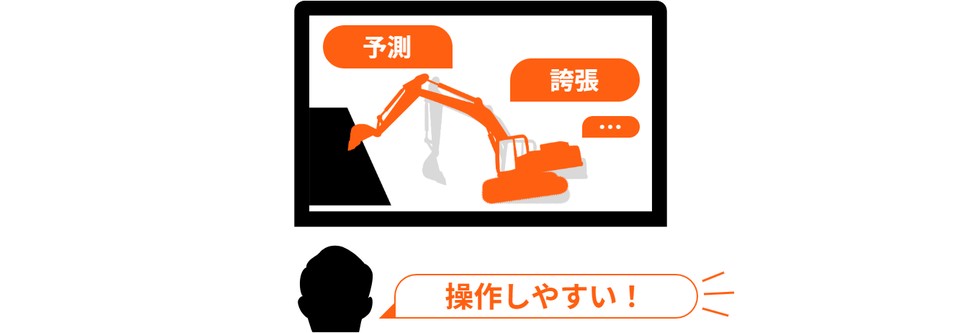
This research seeks to make difficult-to-operate machines easier to control by altering the information presented to the human operator. For example, in an inverted-pendulum task, similar to balancing a rod on the palm of one's hand, continuously displaying future information has been shown to reduce the amount of information required for control. We believe that this reduction makes operation easier and aim to apply the approach to difficult-to-operate real machines such as drones and construction equipment.
Improving Machine-Learning Efficiency through Information Alteration
What students can learn
Students can learn reinforcement-learning theory and implementation techniques using Python. They can gain end-to-end experience from simulation to deployment on physical systems, as well as hardware-oriented development skills such as implementing control on microcontrollers in C.
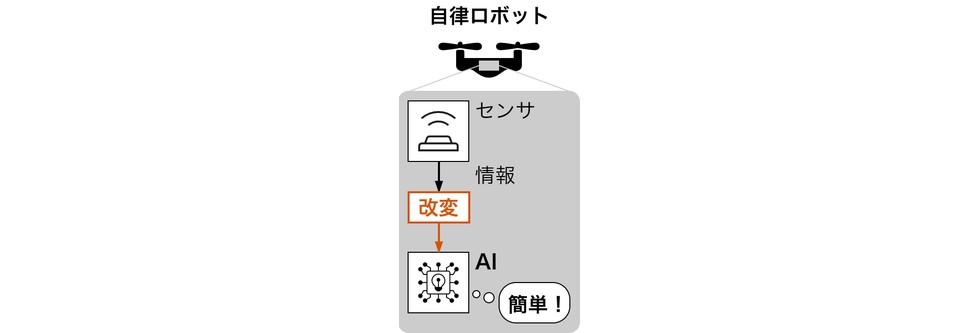
This research seeks to make the learning of autonomous robot control more efficient by altering the information provided to a reinforcement-learning AI. Reinforcement learning enables AI to acquire control methods through repeated trial and error, but obtaining sufficient performance requires enormous amounts of data and time. With the same inverted-pendulum system used in the human experiments, we have confirmed that the amount of training data and time can be substantially reduced while final performance is also improved. We believe this method will also be effective for more complex systems and aim to extend it to applications such as bipedal robots.